Cooperative Networks and Controls Lab · Technion

Mathematical structure behind collective behavior.

We develop theory for networked dynamical and multi-agent systems at the intersection of control, graph theory, geometry, and optimization.

Paper of the week
Representative figure for the featured paper

Our perspective

The questions that drive us

  1. 01
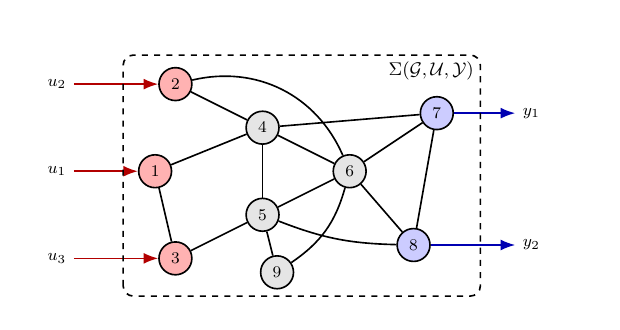
    Network with designated control and output nodes
    Interface structure

    How does network structure shape stability and performance?

  2. 02
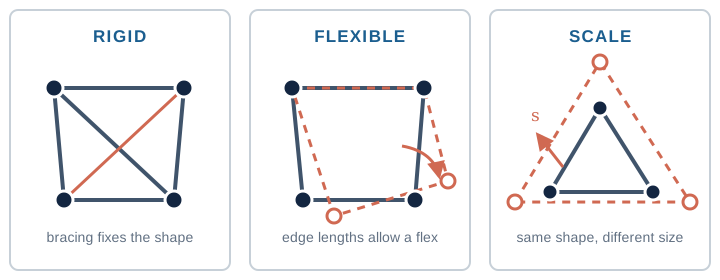
    Rigid and flexible frameworks, together with a shape shown at two scales
    Rigid · flexible · scale

    Which geometric properties make collective objectives achievable?

  3. 03
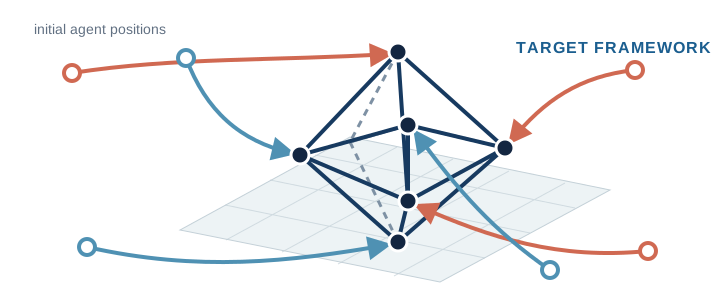
    Three-dimensional agent trajectories converging to a target formation
    Trajectories → target shape

    How can local interactions produce reliable global behavior?

  4. 04
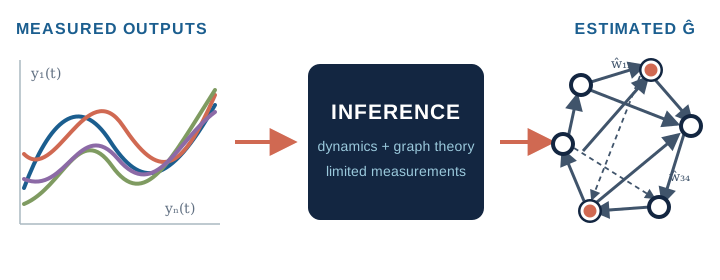
    Observed signals entering an inference method that outputs a network graph
    Measurements → inferred graph

    What can be inferred, optimized, or secured from limited network information?

Notes from the lab

Recent news

News archive →